Application-Tested Handling
Product transfer and pack formation are confirmed around representative samples.
Robotic Palletizing
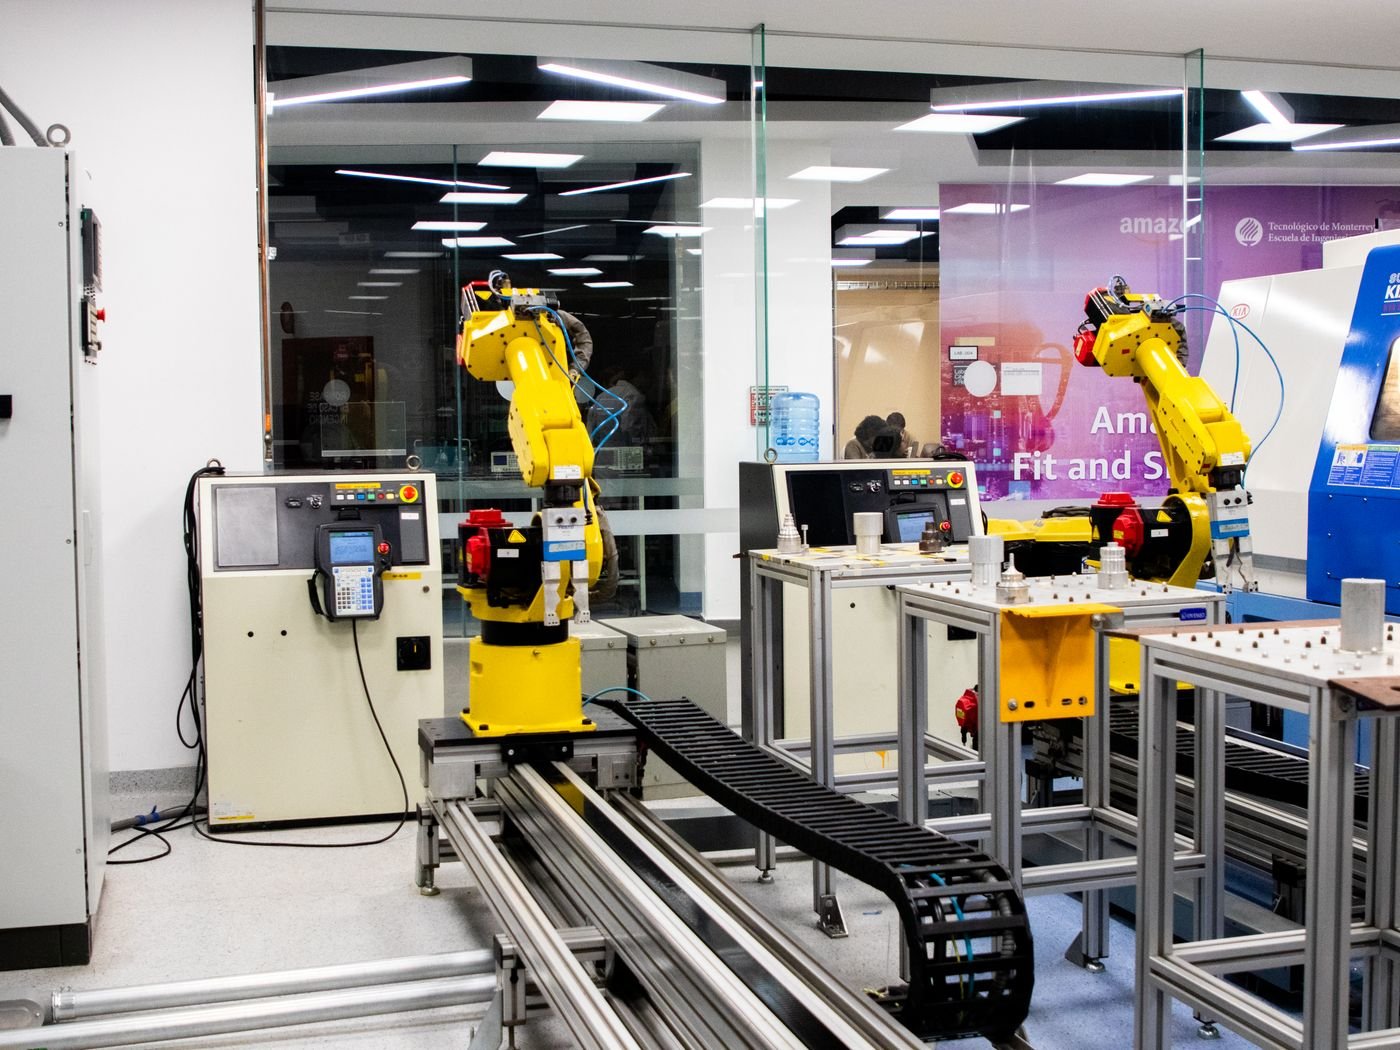
A compact robotic palletizing cell with a product-specific gripper, recipe-based pallet patterns and optional pallet, slip-sheet and wrapper interfaces.
Model RP-1200
A compact robotic palletizing cell with a product-specific gripper, recipe-based pallet patterns and optional pallet, slip-sheet and wrapper interfaces.
Product transfer and pack formation are confirmed around representative samples.
Stored settings and guided adjustments support multiple product formats.
Signals, transfer heights and accumulation logic are defined with adjacent equipment.
Electrical standards, documentation and commissioning scope can be adapted by market.
Equipment Snapshot
Demonstration figures show how a professional equipment page can present the operating range without hiding project-dependent conditions.
Includes product and gripper mass.
Layout depends on SKU and line balance.
Layer and pallet recipes stored in HMI.
Risk assessment defines final devices.
Equipment Overview
The RP-1200 is engineered around case or bag weight, pickup orientation, pallet size, pattern stability, line rate and the available safety footprint. The cell can receive one or multiple product lanes and manage several pallet recipes through the HMI.
Robot payload is only one selection factor. Required reach, cycle time, gripper weight, approach path, pallet height and pallet exchange time are evaluated together to avoid an undersized or unnecessarily large robot.
The delivered scope can include pallet dispensers, slip-sheet handling, product identification, pallet conveyors, stretch-wrapper communication and central line status.
Technical Specifications
Final values are confirmed after sample, layout, utility and interface review. Each row can include an explanatory note instead of presenting isolated numbers.
Selected by reach, cycle and handling path.
Maximum and minimum weights are confirmed.
Pallet dimensions and entry direction are defined.
Selected after product and layer-pattern review.
Includes pallet, product stack and slip sheets.
Dispenser and conveyor options available.
Line interface and recipe ownership are defined.
Final concept follows the cell risk assessment.
Project Advantages
These benefits come from application review, defined interfaces and measurable acceptance criteria rather than decorative feature claims.
Store multiple layer and pallet recipes for approved products and pallet sizes.
The gripper is designed around product rigidity, porosity, weight and pickup orientation.
Infeed accumulation and pallet exchange are included in the cycle-time study.
Guarding, access, interlocks and restart behavior are reviewed during FAT.
Typical Applications
Application suitability is confirmed against real samples, speed and environmental conditions before the final machine configuration is released.
Vacuum, clamp or layer handling for regular secondary packages.
Supported gripping and controlled placement for deformable products.
Pattern building for open trays, shrink bundles and multipacks.
One robot can service several infeeds when cycle and reach studies permit.
Configuration & Integration
A complete quotation identifies what the machine receives, what it delivers and which functions belong to adjacent equipment or the customer site.
Transfer height, product orientation, access, guarding and installation clearances.
Power, safety, run permission, fault status, speed references and network connections.
Samples, utilities, local work, lifting, installation, validation and site acceptance responsibilities.
Operating Sequence
Each cycle is coordinated with product arrival, pallet status and the selected pattern recipe.
The cell confirms the active SKU and pallet recipe from the line or operator selection.
Products are stopped, oriented or grouped at a repeatable robot pickup position.
The robot picks the product with monitored vacuum, clamp or tool status.
Products are placed according to the stored pattern and stack-height calculation.
Completed pallets leave the cell and an empty pallet is positioned for the next load.
Configuration Comparison
Use the same comparison factors when evaluating competing technical proposals.
| Selection Factor | Vacuum | Clamp | Layer / Fork |
|---|---|---|---|
| Best for | Sealed cartons and rigid surfaces | Cases, trays and stronger packs | Full layers or unstable individual packs |
| Product contact | Top surface | Side compression | Bottom or full-layer support |
| Key validation | Porosity and surface quality | Compression tolerance | Layer formation and support access |
| Tool weight | Low to medium | Medium | Medium to high |
| Typical flexibility | High for regular cartons | Good with adjustable clamps | Best for high-volume layer handling |
Technical Review
Each tab answers a different procurement question and demonstrates a deeper product-content structure.
Robot motion, pickup confirmation, layer placement, slip sheets and pallet exchange are included. The study uses the highest and lowest line rates, not only an average.
Product samples are checked for porosity, rigidity, deformation, surface marking and pickup repeatability before the final tool concept is approved.
Manual exchange, dispensers, pallet conveyors, slip sheets and stretch-wrapper interfaces are planned as one material-flow system.
Doors, scanners, light curtains, maintenance access and recovery procedures are developed from the final cell layout and risk assessment.
Robot programs, PLC backups, gripper wear parts, training and remote support are included in the lifecycle plan.
Factory Acceptance Testing
Testing uses agreed samples, functions and acceptance methods. Project-dependent items are recorded rather than hidden.
Confirm robot capacity with the final gripper and highest pallet position.
Run each agreed pattern and verify orientation, layer alignment and stability.
Check empty pallet supply, full pallet discharge and accumulation behavior.
Test access devices, interrupted cycles and controlled restart procedures.
Confirm operator functions, maintenance access and software backup delivery.
Procurement Risk Review
A professional product page should make risk and project assumptions visible, not only list attractive features.
Rated speed is quoted without product and operating assumptions.
Tie output to approved samples, format, buffer condition, reject logic and FAT method.
Machine boundaries and adjacent-equipment responsibilities are unclear.
Approve a layout, interface list and responsibility matrix before manufacturing.
Installation and ramp-up support are discussed after shipment.
Define site readiness, commissioning, training, spares and remote support in the project scope.
Project Documents
These demonstration resources show how an independent site can present technical depth and reduce uncertainty before inquiry.
Equipment FAQ
The answers identify what must be confirmed during technical review instead of presenting unsupported guarantees.
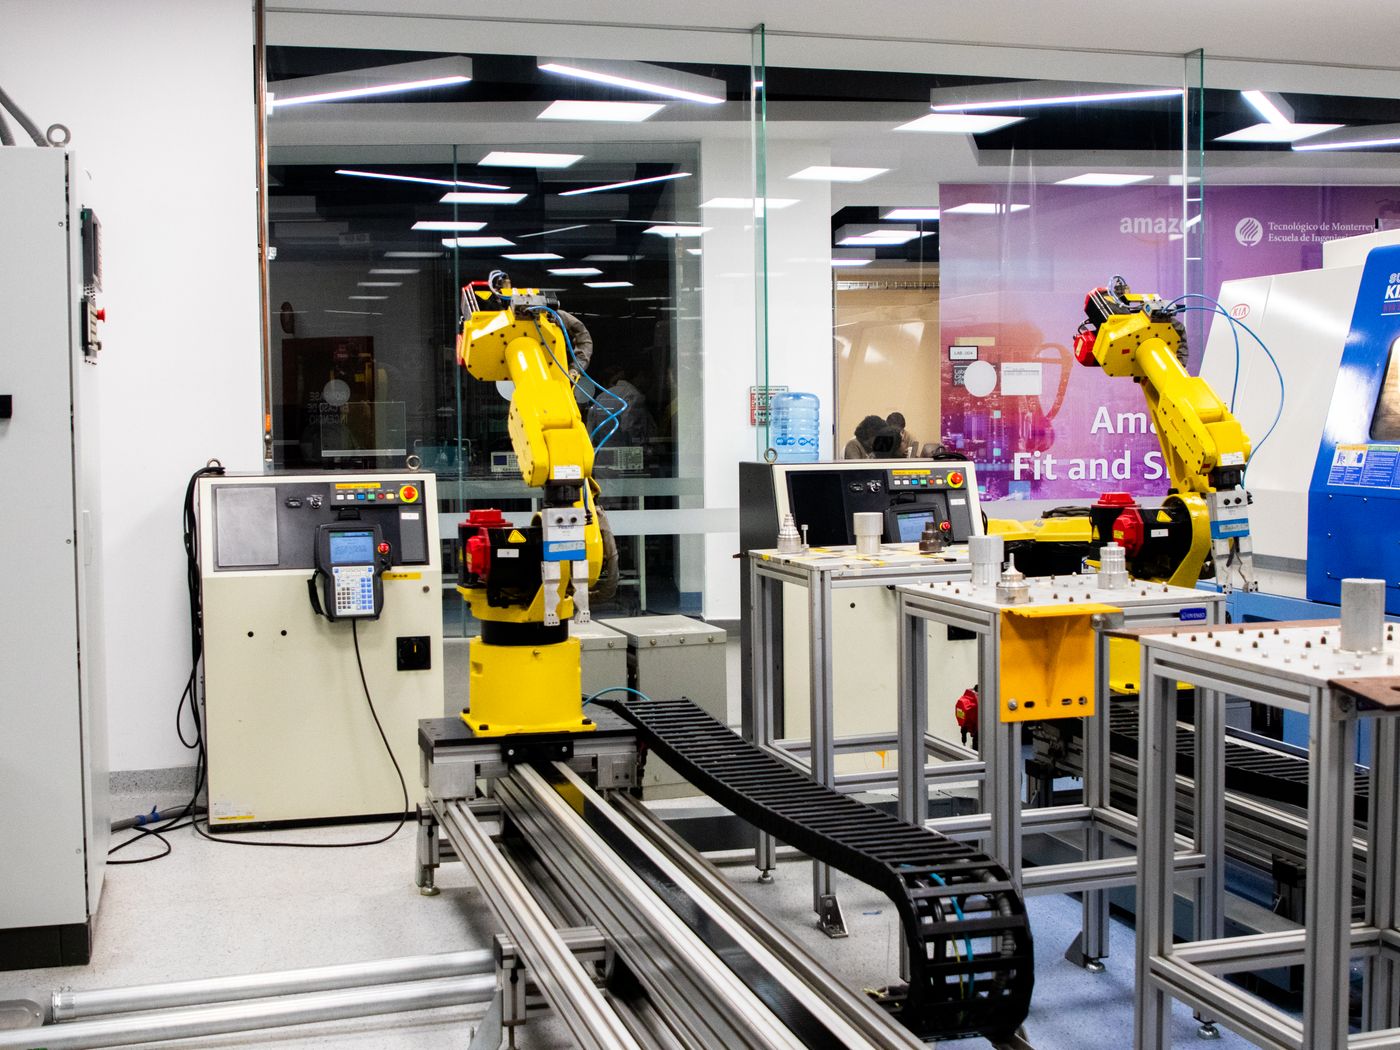
Payload, gripper weight, reach, pallet height, cycle time and motion path are calculated together. Selecting by product weight alone can lead to the wrong robot.
Yes. The number of SKUs depends on gripper compatibility, infeed arrangement, pattern recipes and the required changeover method.
Yes. Pallet dispensers, slip-sheet magazines and pallet conveyors can be included when the layout and cycle study justify them.
The footprint depends on robot reach, product infeeds, pallet positions, guarding, maintenance access and pallet logistics. A scaled layout is prepared before order confirmation.
Yes. Conveyor handover, pallet tracking, signal exchange and accumulation can be defined as part of the integrated end-of-line scope.
FAT covers agreed products, patterns, cycle rate, gripper monitoring, pallet exchange, safety functions, alarms and operator recovery procedures.
Related Equipment
Review upstream, downstream and complementary equipment using the same structured product system.
Buyer Resources
Long-form selection guides help buyers prepare better inputs, evaluate suppliers and define acceptance criteria.
Request a Technical Proposal
Attach representative product photos, drawings, packaging information or a short production video. The first response should identify missing technical inputs and a practical next step.